|
Leo Huang I am a robotics researcher at Berkeley AI Research (BAIR) and the EMBER Center, advised by Prof. Shankar Sastry and working closely with Prof. Claire Tomlin. I received my M.S. in EECS from UC Berkeley, following B.S. degrees in EECS and Bioengineering. Previously, I worked on vision-language navigation with Prof. Koushil Sreenath, DNA origami nanofabrication with Prof. Grigory Tikhomirov, and magnetic particle imaging with Prof. Steven Conolly. My research focuses on humanoid and mobile manipulators that can safely provide physical assistance to people, particularly rapid and measurable adaptation, multimodal spatial memory, and whole-body dexterous manipulation. I want to teach robots resourceful, creative problem solving, such as reshaping their surroundings to reach a goal, and to build learning-based whole-body controllers with formal safety guarantees. |
|
News
|
Publications* denotes equal contribution. |
|
FARM: Find Anything using Relational Spatial Memory
Siming He, Leo Huang, Adam Lilja, Fabio Huebel, Jonas Frey, Marco Pavone, S. Shankar Sastry, Jitendra Malik, Claire Tomlin arXiv, 2026 project page / arXiv A real-time, open-vocabulary object memory that answers queries describing an object by its relations to landmarks and nearby objects. Across 44k queries in 67 indoor and outdoor scenes, FARM improves Recall@5 by 164% over prior methods, and it runs closed-loop on a quadruped. |
|
|
Double-T DINER: Deploying Improvements in New Environments via Refined Tool Transfer
Henry Tsai*, Leo Huang*, Denae Cantrell*, Narek Harutyunyan, Hunter Tsai, Maggie Dong, David Jo, Claire Tomlin, S. Shankar Sastry CoRL 2026 - Sim2Real2Field Workshop, 2026 project page A refiner agent edits a Spot robot's pick-and-place tools in simulation, and we test whether the edits that help in simulation also help in real-world field trials. |
|
 |
Precision Placement of DNA Origami onto Patterned Silicon Wafer Surfaces
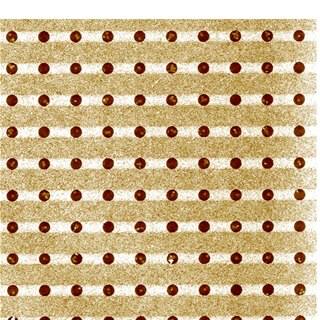
Leo Huang M.S. Thesis, UC Berkeley EECS, 2025 (Technical Report UCB/EECS-2025-76) tech report Placed hexagonal DNA origami onto patterned silicon wafers and raised single-origami binding yield 4x by tuning buffer conditions and deposition methods. |
 |
Broadband Untuned Active Cancellation and Phase Correction of Direct Feedthrough Interference Enables 100-fold Improved Magnetic Particle Imaging Detection
Q. Huynh, O. Doyle, K. Guo, A. Swamynathan, L. Huang, J. Garlepp, N. Dambal, J. Bryan, S. Ramdani, C. Saayujya, B. Fung, Y. Lu, B. Fellows, O. Sehl, S. Conolly TechRxiv, 2023 preprint An untuned active cancellation circuit removes direct feedthrough interference in magnetic particle imaging and improves detection 100-fold. |
Projects |
 |
Project Pigeon
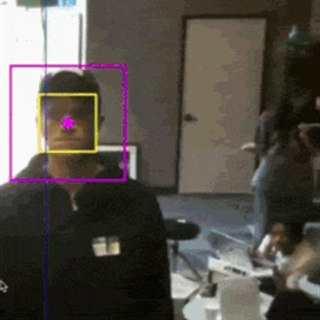
1st Place, Bee AI Hackathon, 2025 code Voice-command control for a DJI Tello drone, combining open-vocabulary (OWL-ViT) and real-time (YOLO) detection with a PID controller for vision-based closed-loop flight. |
Honors
Teaching
|
|
Website template from Jon Barron. |